
Key Takeaways
- Acoustic detection emits no radar or RF signal, so it cannot be located by the drone operator it is hunting.
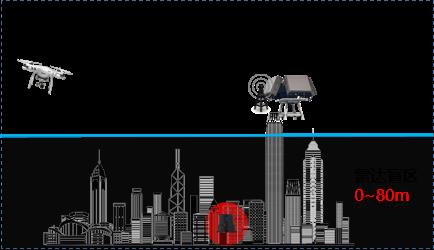
- It covers the 0–80 m altitude band and the sub-12 m treeline gap where radar and cameras lose the target.
- A patented cavity-resonance pickup reaches 99.6% classification accuracy on complex-environment sounds.
- A ResNet34-based edge model returns a detection decision in 0.1–0.2 seconds at under 1.5 W.
- Site cost is roughly 1/20 of a microphone-array deployment, and each unit installs in about two minutes.
Passive acoustic drone detection works by listening rather than radiating: a sealed resonant cavity picks up the drone’s rotor signature and an edge AI model classifies it on the spot. As of 2026 it has become the standard way to fill the gaps that radar, RF and optical sensors physically cannot cover.
Where Radar, RF and Optics Stop Working
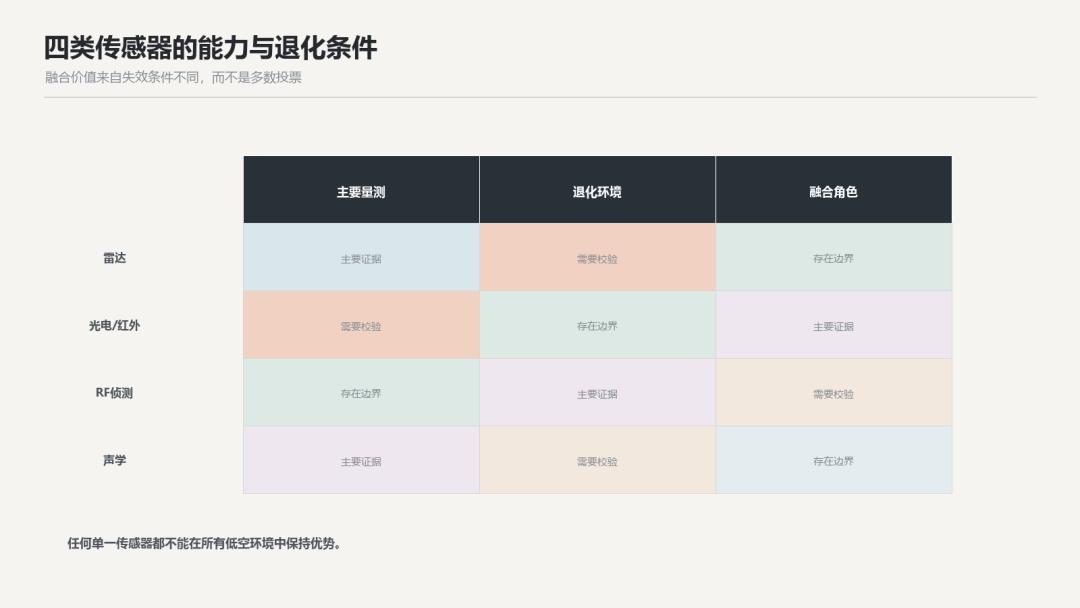
Every detection method in a counter-UAS system has a hole in it. The four mainstream technologies break down as follows.
| Method | Strengths | Limits |
|---|---|---|
| Radar | Long detection range, rich target information | High cost; cannot see close-in, low, slow, small or non-conducting targets; radiates, so it can be located and attacked |
| Radio frequency | Long range; can intercept traffic and seize control | Costly; blind to drones that are not transmitting, or that carry frequency-hopping countermeasures |
| Optical / video | Useful for visual tracking of a confirmed target | Not a primary detection method; degraded by fog, rain, snow, dust and haze |
| Acoustic | Emits nothing, so it stays covert; covers the radar low-altitude blind zone; supports bearing cueing; low cost; flexible siting | Microphone-based products suffer badly from environmental noise and contamination |
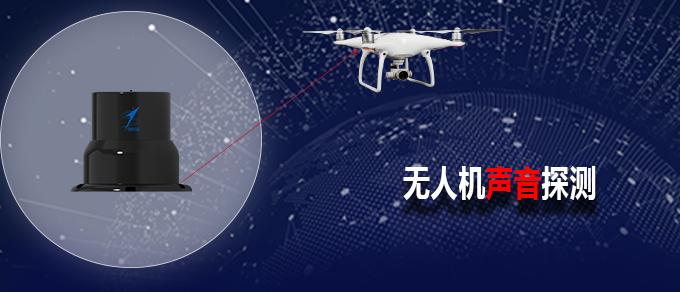
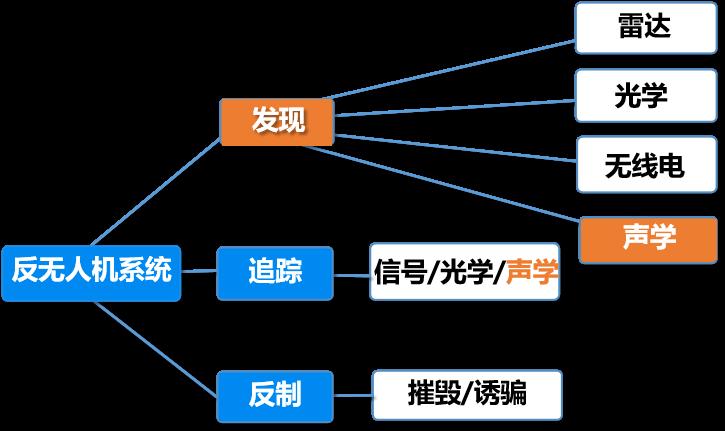
Three gaps keep showing up in real deployments: radar is blind below roughly 80 m, RF detection is useless against fibre-optic tethered drones that never radiate, and video cannot see below a 12 m treeline. Sound is the best remaining way to close all three.
How a Passive Acoustic Resonance Sensor Works
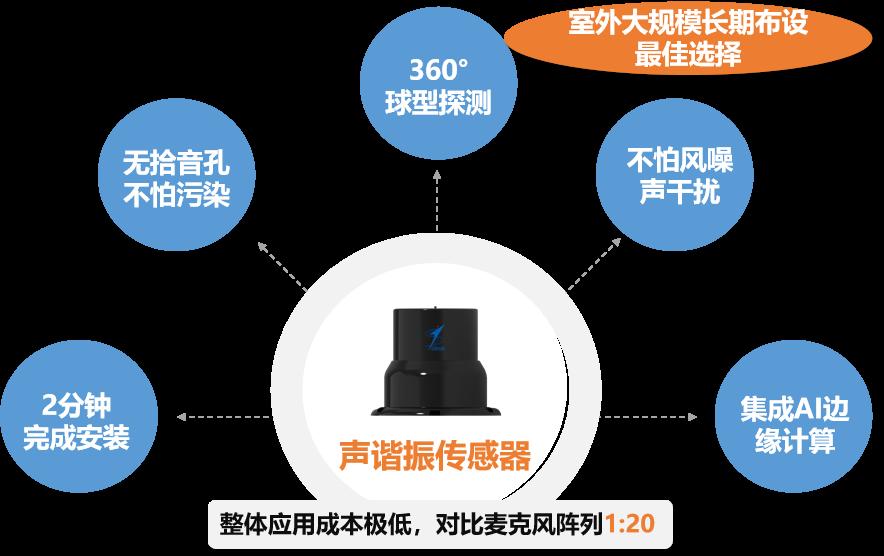
The sensor is built on four ideas: cavity resonance sensing, integrated AI edge computing, flexible networking and flexible power.
Noise Rejection in Two Stages
Noise rejection happens twice — once in physics, once in electronics.
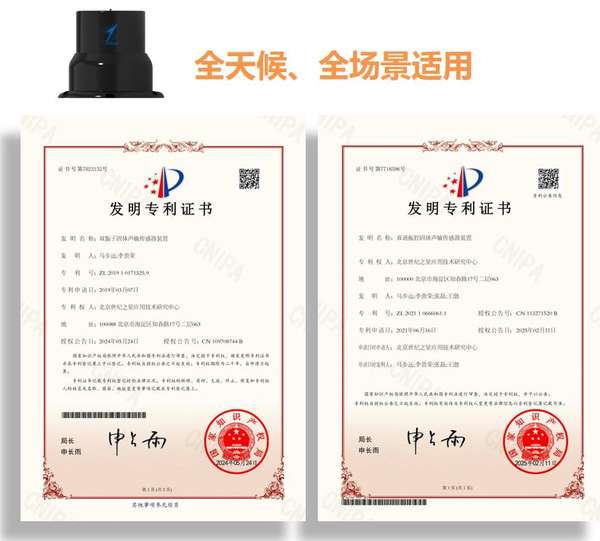
On the physical side, a patented cavity resonance structure is tuned to a set resonant frequency, which suppresses ambient sound before it ever reaches a transducer. Because the cavity is sealed with no pickup hole, wind cannot disturb it and surface contamination cannot block it. Patent ZL202110666061.1.
On the electronic side, frequency selection, tracking and resonant amplification suppress what remains of the ambient noise. Patent ZL201710074153.4.
The combination is what separates this approach from a microphone: the dual physical-and-electrical noise suppression means the unit is not affected by wind and does not care about surface dirt.
AI Sound Classification
The classification model is pre-trained at scale and then distilled onto the sensor.
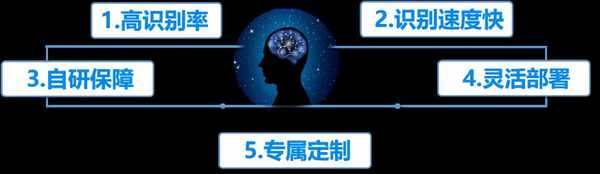
- Accuracy: 99.6% on sound classification tasks such as digging, knocking and footsteps in complex environments.
- Speed: built on a ResNet34 deep residual network with heavy algorithmic optimisation, returning a detection decision in a 0.1–0.2 second window.
- Ownership: the residual-network algorithm and decoding method are developed in-house, so accuracy is not dependent on a third-party model.
- Deployment: cloud invocation through online API or SDK, with the model dedicated to the customer once live.
- Customisation: on-site learning lets the unit adapt to a specific site’s acoustic environment in one to two days of training.
Everything on the Sensor
Sensing, AI compute, communications and power are all integrated into the sensor itself, so it can run standalone with no network at all. That matters in a jamming scenario: the unit still finds the drone when the backhaul is down.
| Subsystem | Implementation |
|---|---|
| Acoustic front end | Cavity resonance sensing, omnidirectional, immune to surface contamination |
| AI compute | Server-side model distilled and quantised onto an on-board AI chip for edge inference |
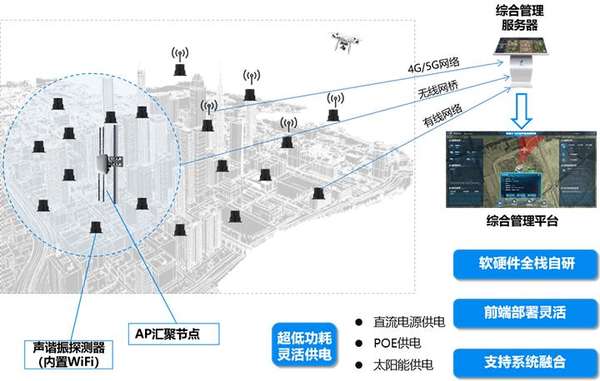
| Power | DC supply, battery, PoE or solar |
| Networking | WiFi, 4G/5G, wired Ethernet or wireless bridge |
| Reporting | MQTT or HTTP POST for real-time events |
| Live monitoring | RTMP or WebSocket streaming |
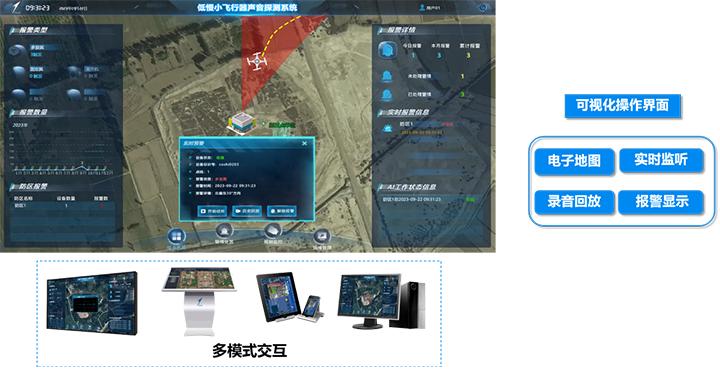
| Management | Web console with status overview, live listening, recording playback, system settings, firmware and model OTA |
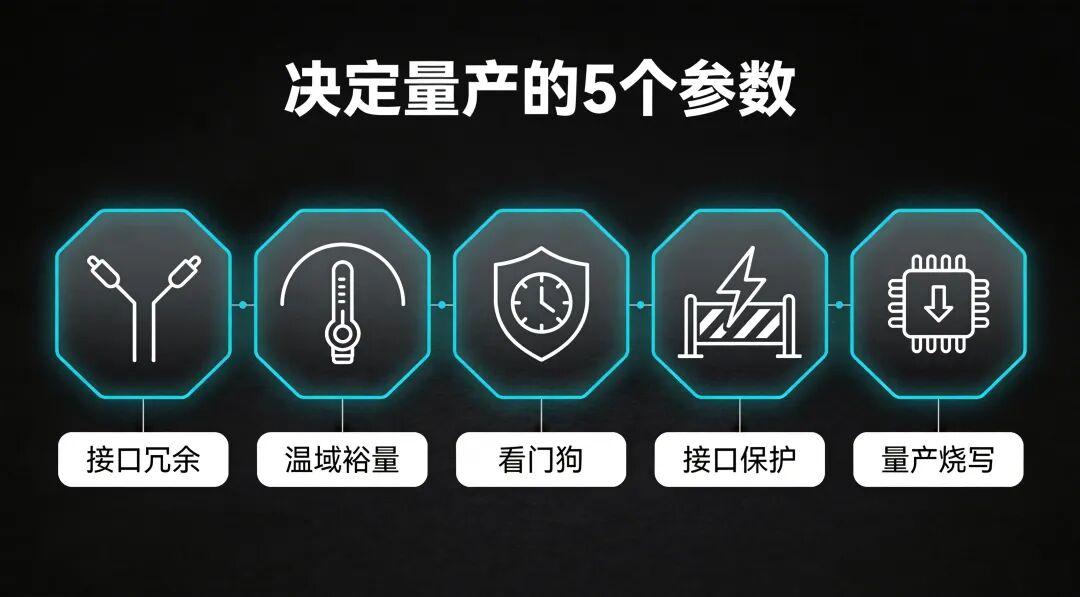
| Consumption | ≤1.5 W, with watchdog, power-fail protection and resource monitoring |
Networking and the Operator Console
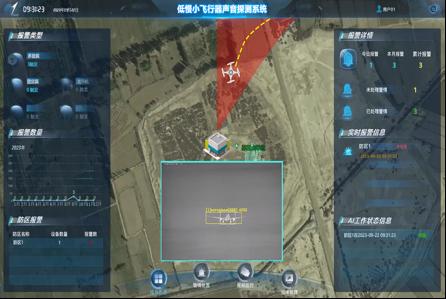
Units form a mesh through WiFi, cellular, wired links or a wireless bridge, aggregating at an edge node before reaching the management platform.
Adding Video Tracking
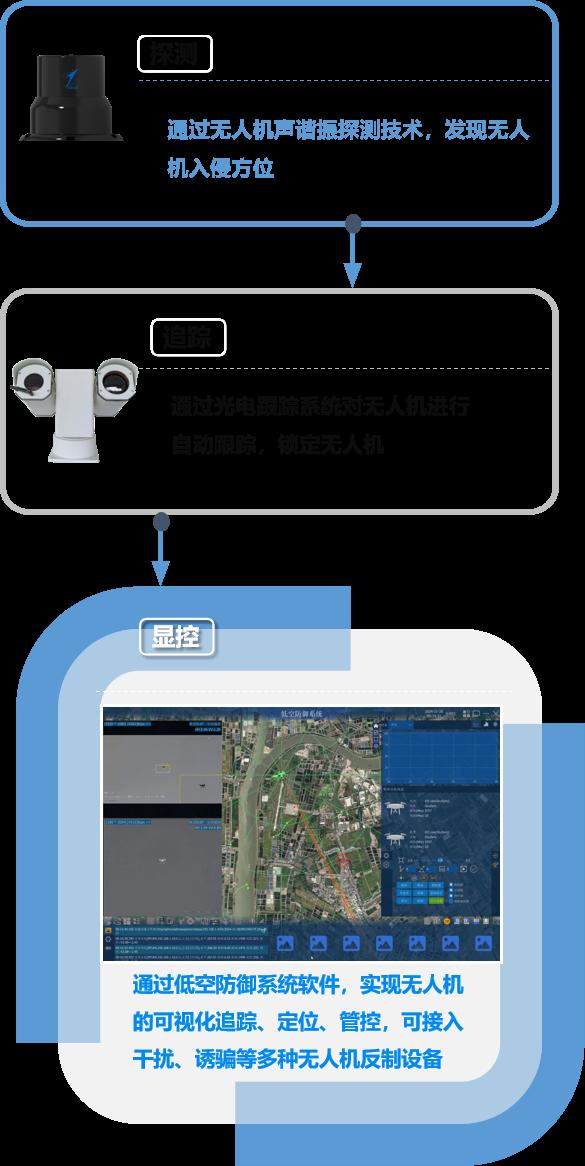
Acoustic detection is a cueing sensor, and it pairs naturally with a camera. Target detection uses YOLO-family models with neural-network and deep-learning back ends, and already covers more than 80 classes including people, vehicles, boats, aircraft, birds, animals and smoke.
Tracking runs KCF and long-term motion tracking, complex-background tracking, inertial-navigation-assisted tracking and repeated-detection tracking, which together handle linear tracking and high-speed dynamic targets.
Acoustic Resonance vs Microphone Arrays
The comparison that matters is against the microphone array, the incumbent acoustic approach.
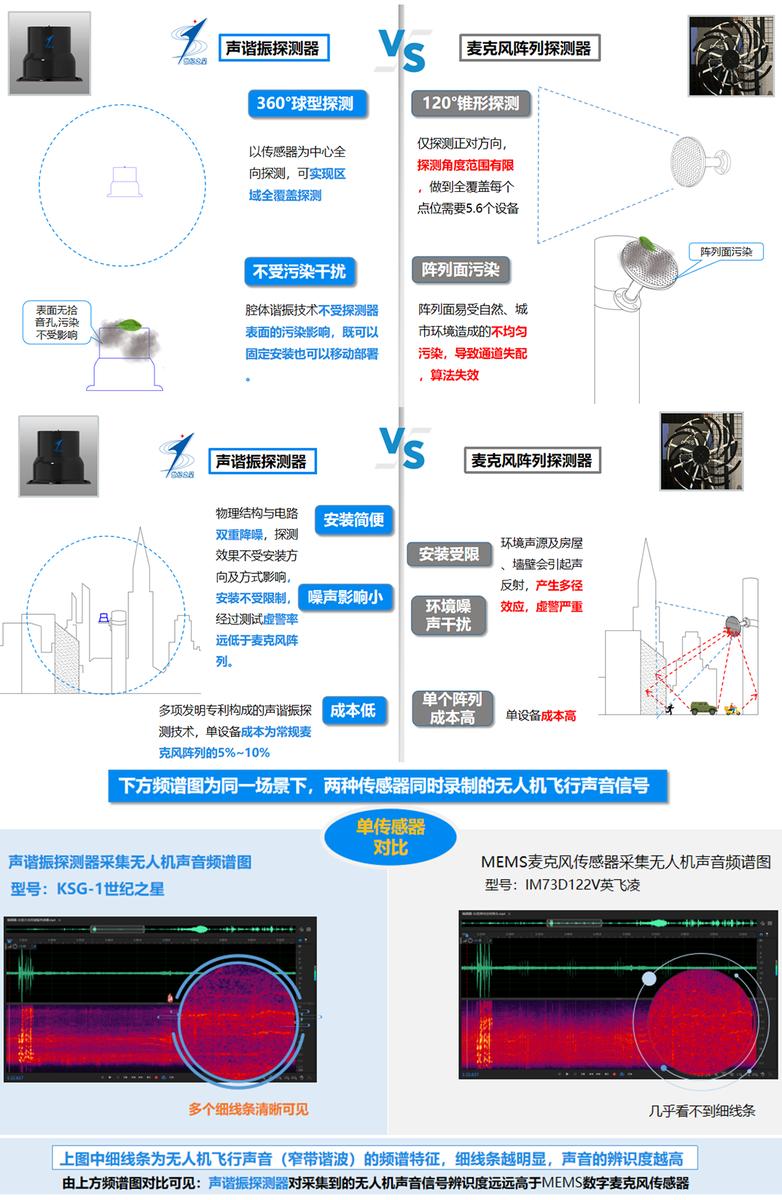
A microphone array needs an open acoustic path, which means wind screens, periodic cleaning and a noise floor that rises with the site. A resonant cavity trades broadband pickup for selectivity: it hears less of everything else, which is precisely why it can sit outdoors for years without maintenance.
Deployment Geometry
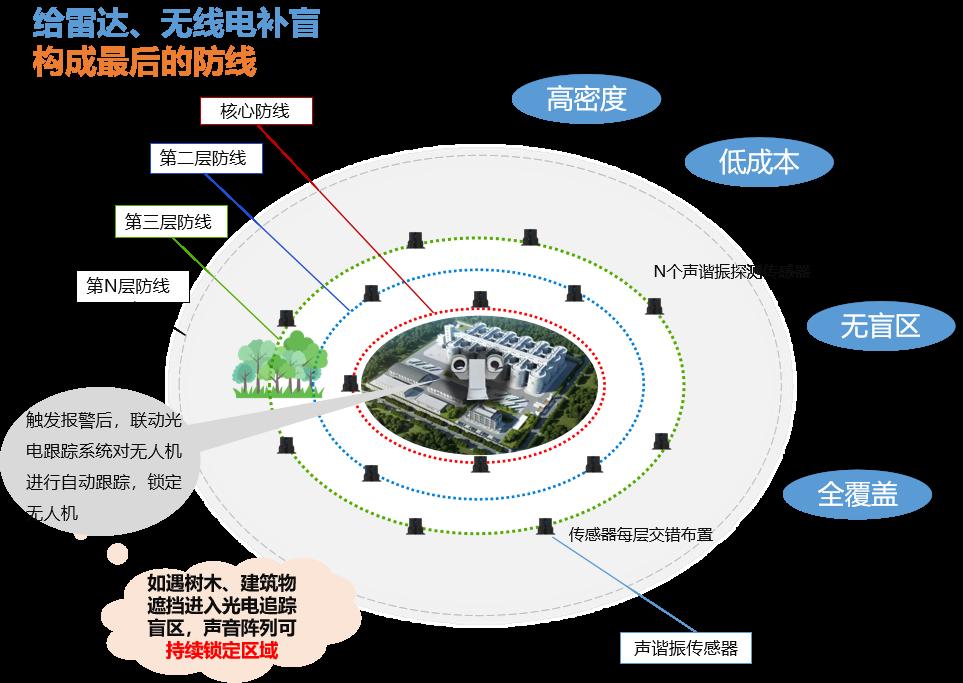
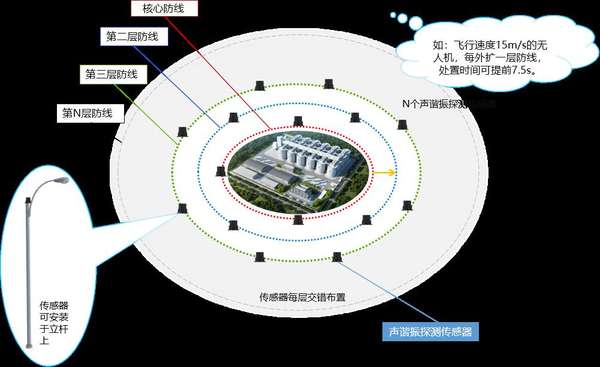
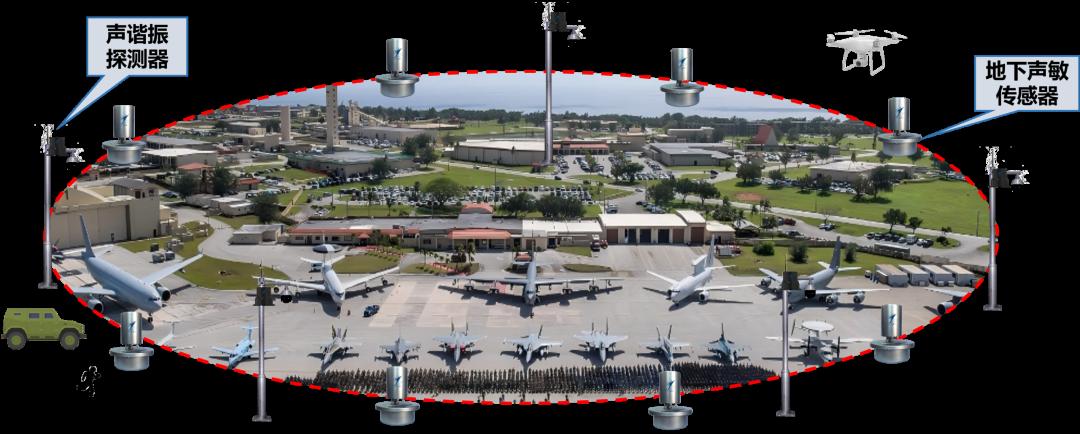
Coverage is built in concentric layers around the protected asset. For a site with a 4 km perimeter, the core layer places sensors every 100 m for a total of 40 units. A second layer sits 100 m further out with the same 100 m spacing, requiring 48 units. A third layer adds another 100 m and 56 units.
Each additional layer adds eight units over the layer inside it while stepping out 100 m, building depth into the defence. Every extra ring buys response time, because the outer layers detect the drone earlier.
Where It Gets Deployed
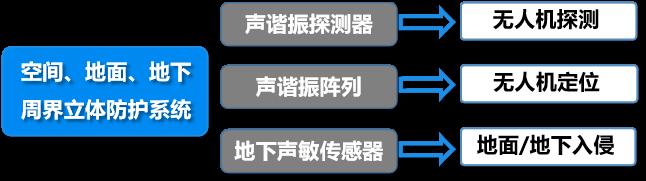
Because the detector emits nothing, it is hard to find and hard to spoof, and it works alongside radar and RF rather than replacing them.
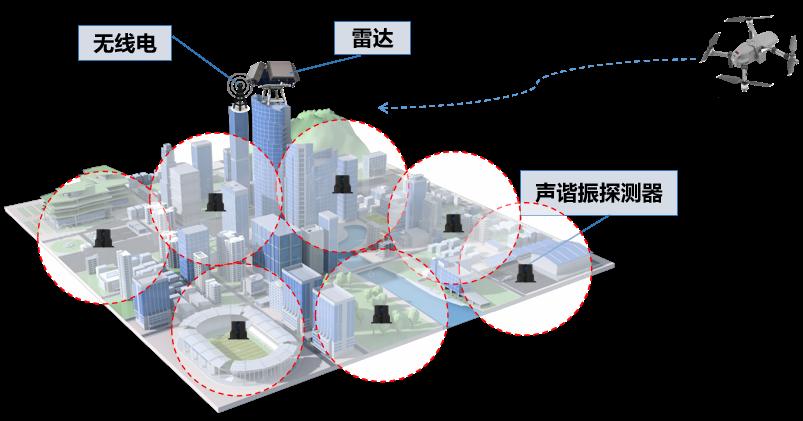
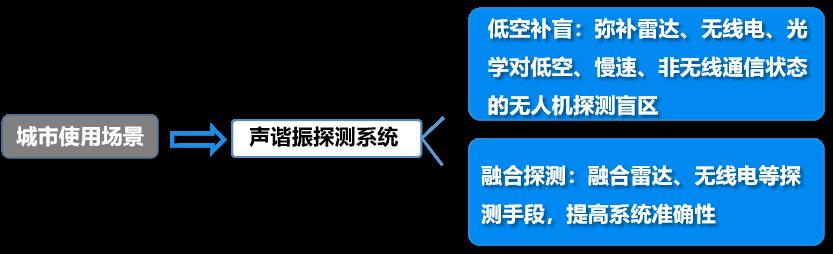
- Safe city programmes: fills the low-altitude gap and cues radar and RF sensors onto the target.
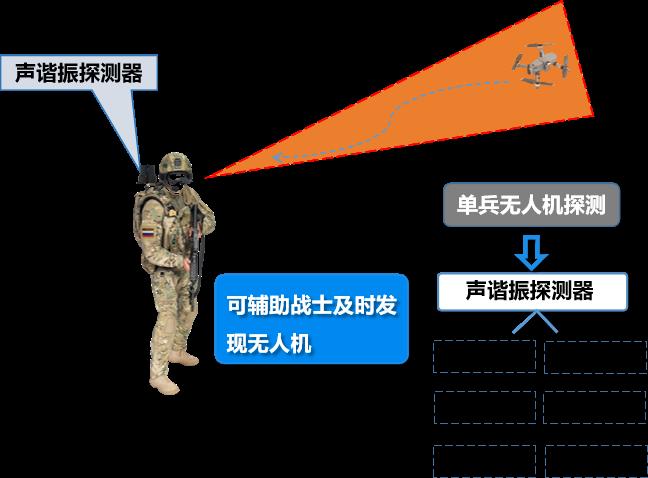
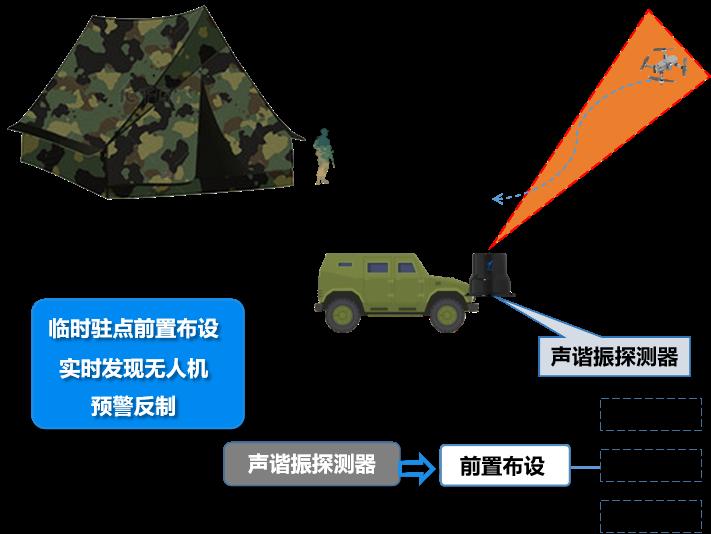
- Dismounted use: a single soldier can carry a unit and get a bearing to an incoming drone.
- Fixed sites and perimeters: continuous monitoring of a defined boundary.
- Temporary outposts: tripod or vehicle mounting for short-duration operations.
Have questions about this article? Feel free to contact us at [email protected] — we’re happy to help!
Frequently Asked Questions
How does acoustic drone detection work without emitting a signal?
A sealed resonant cavity tuned to a specific frequency picks up the rotor’s acoustic signature, and an on-board AI model classifies it. Nothing is transmitted, so the sensor cannot be detected by the drone or its operator.
What range and altitude can acoustic detection actually cover?
It is designed for the low-altitude band, notably 0–80 m where radar struggles, and for the sub-12 m treeline gap where cameras lose line of sight. Detection range depends on the drone’s rotor noise and the site’s ambient sound floor.
How accurate is the sound classification?
99.6% on complex-environment sound classification tasks such as digging, knocking and footsteps. Detection decisions are returned in 0.1–0.2 seconds using a ResNet34-based model running on the sensor itself.
Does wind or dirt degrade a resonant cavity sensor?
No. The cavity is sealed with no pickup hole, so wind cannot enter and surface contamination cannot block the acoustic path — the two failure modes that most often take microphone arrays out of service.
How many sensors does a typical perimeter need?
For a 4 km perimeter with 100 m spacing, the core layer needs 40 units, a second ring 48 and a third 56, with each additional ring adding eight units and stepping out 100 m to buy response time.
About Aomway
Aomway has been developing and manufacturing video transmission and UAV radio hardware for over 15 years, producing equipment for any frequency band from 1 GHz to 9 GHz at power levels from 3W to 15W. We build high-power FPV video transmitters, directional and circularly polarised antennas, digital links, fiber-optic tether systems and detection hardware for pilots, integrators and commercial operators worldwide.